Plenary talk at the Intern. Conf. on Practical Applications of Agents and Multi-Agent Systems (PAAMS), Naples, Italy, October 21, 2026
Abstract
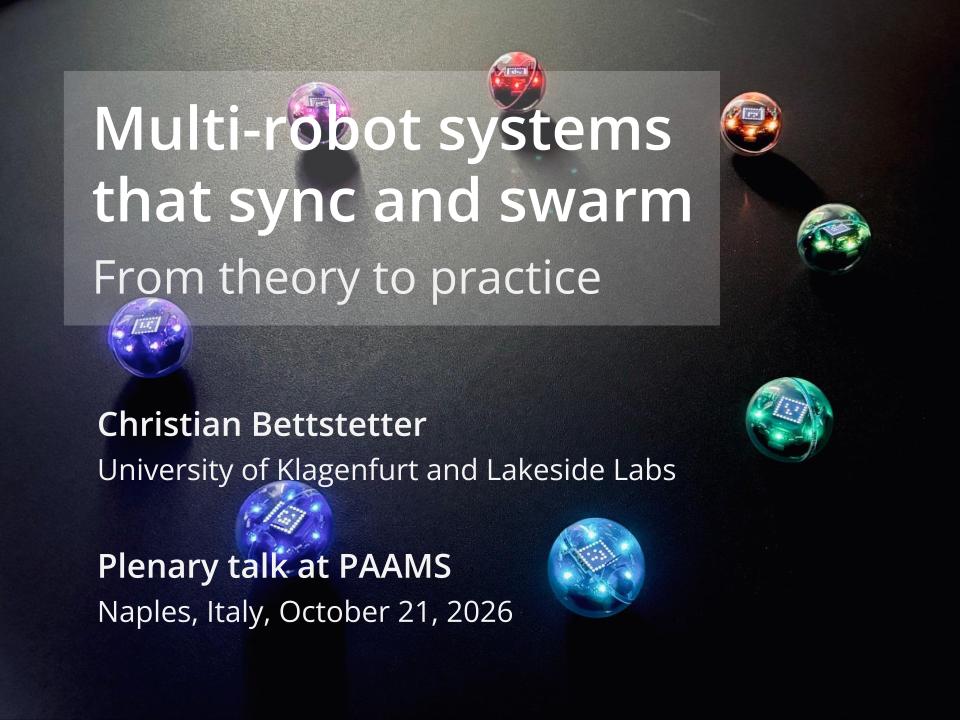
Click to view the slides and videos (available soon).
How can multiple agents coordinate their timing and movement to produce coherent collective behavior? This talk explores the interplay between synchronization and swarming, following the path from theory to practical applications.
The first part introduces self-organized synchronization and its transfer to wireless systems. The second part covers the theory and practice of swarmalators — a unified approach that interweaves synchronization and swarming to generate a variety of emergent spatiotemporal patterns. Bettstetter shares insights from his group’s work on implementing swarmalators in multi-robot and multi-drone systems. He discusses practical challenges, including limited communication ranges and other constraints, and presents building blocks to realizing swarmalator behavior in real-world technical systems.
Speaker bio

Photo by D. Waschnig / U Klagenfurt
Christian Bettstetter is professor of mobile systems at the University of Klagenfurt, Austria, where he heads the Institute of Networked and Embedded Systems. He also serves as scientific director of Lakeside Labs, a research and innovation company. He earned his doctoral degree (summa cum laude) in electrical engineering and information technology from Technische Universität München, Germany. His research group focuses on wireless communications and self-organization in networked systems, with applications spanning telecommunications, robotics, and drones. Bettstetter has received several scientific awards, including best paper awards at IEEE ACSOS and SASO. His dedication to teaching was recently honored with the excellence in teaching award of his university.